 Nila Kartika Wati
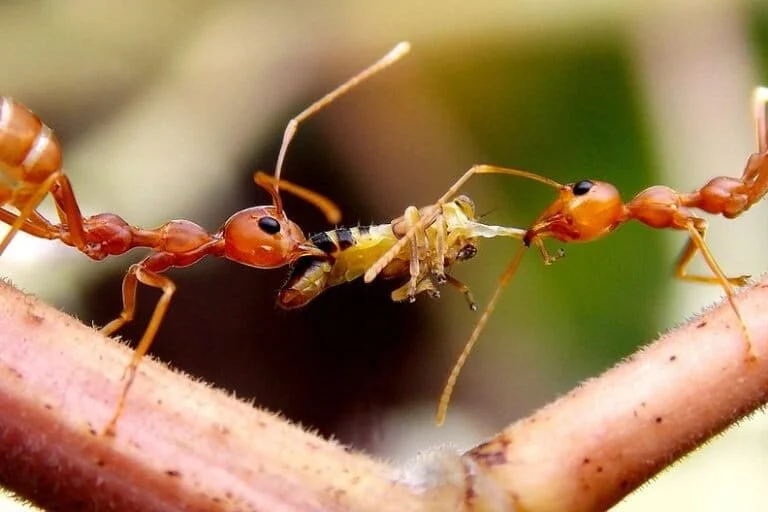
In the arid, unforgiving landscapes of the Spanish desert, the Saharan silver ant and its relative, the Cataglyphis velox, perform a daily feat of biological engineering that continues to baffle behavioral biologists. When these insects discover food resources too cumbersome to carry in their mandibles, they resort to a curious and physically demanding method of transport: they drag the payload while walking backward toward their nest. This behavior raises a profound question in the field of sensory ecology: how does a creature maintain a precise heading toward its home when its visual field is perpetually directed away from its destination?
Recent investigations led by researcher Sebastian Schwarz have provided a clearer, though complex, picture of the mechanisms involved. By observing these ants in both natural and controlled desert environments, scientists have begun to decode the multi-sensory navigation system that allows Cataglyphis velox to traverse vast distances without the benefit of forward-facing vision.
The Mechanisms of Insect Navigation
Foraging ants are not merely wandering; they are sophisticated map-makers. The primary method utilized by these insects is known as path integration, an innate form of dead reckoning. As an ant travels away from its nest, it continuously tracks its movements—measuring the distance covered and the turns taken—to compute a direct vector back to its point of origin.
However, path integration is only one component of the ant’s toolkit. These insects are also masters of celestial navigation. By utilizing the position of the sun as a compass, they can maintain a consistent heading even when the path is obstructed. Furthermore, they are highly sensitive to visual landmarks, capturing panoramic snapshots of their surroundings that they store in their miniature brains for comparison during the return trip. The fundamental challenge, as identified by Schwarz and his team, is how the ant integrates these navigational inputs while its body is effectively moving in reverse.
Experimental Design and Behavioral Observations
To understand this phenomenon, researchers conducted a series of controlled field experiments in Spain. The study focused on the behavioral transitions of ants tasked with dragging heavy cookie crumbs—a stand-in for large prey items—back to their colonies.
The methodology involved placing "distractor" objects, such as black plastic bags and large tarpaulins, along the established foraging trails. These physical alterations were designed to test how environmental familiarity influences an ant’s decision-making process. The results were telling: when the landscape was familiar, the ants could maintain their backward course for nearly six meters before needing to turn around to re-orient themselves. In contrast, when the landscape was obstructed or altered with artificial markers, the ants stopped to check their orientation after traveling only 3.2 meters.
These findings suggest that the ants are not merely relying on a stored internal compass, but are actively sampling the visual environment even while moving backward. By periodically turning to face their direction of travel, they "re-calibrate" their position against the stored visual memory of the path.
Chronology of Foraging and Transport
The behavioral sequence of a Cataglyphis velox ant during a foraging trip follows a distinct chronology:
- Outbound Exploration: The ant ventures from the nest, utilizing path integration and celestial cues to map the territory.
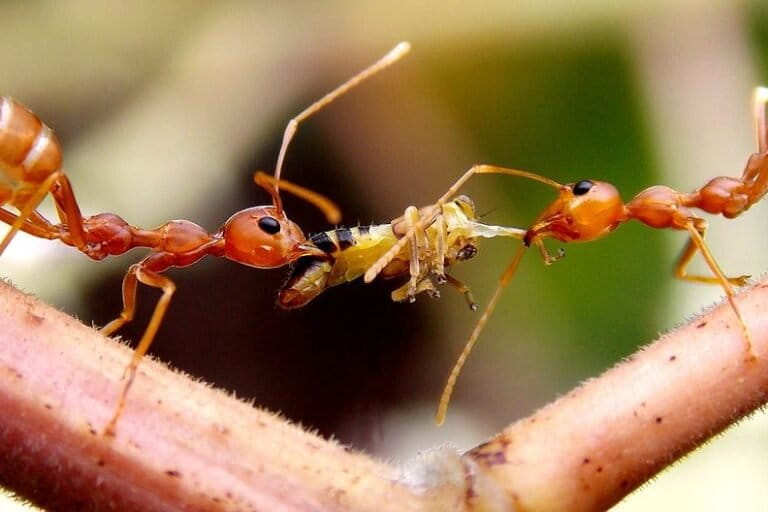
- Resource Discovery: Upon finding food that is too large for standard transport, the ant switches to a "reverse-dragging" mode.
- Information Sampling: During the trek home, the ant intermittently releases the food to rotate its body, scanning the horizon to match its current view with the stored "home-bound" visual data.
- Correction and Adjustment: If the visual cues are mismatched due to environmental changes or an incorrect heading, the ant stops more frequently to re-orient.
- Nest Arrival: Using a combination of local cues and vector summation, the ant completes the journey.
Neuroethological Perspectives and Expert Analysis
Pauline Fleischmann, a renowned neuroethologist who has extensively studied insect navigation, describes the work of Schwarz and his colleagues as a landmark in behavioral research. According to Fleischmann, the study highlights the incredible plasticity of the insect brain.
"The ability of an ant to process visual information from the periphery while its primary sensory input is directed away from the path is a testament to the efficiency of their visual systems," Fleischmann noted in a peer commentary. She emphasizes that the wide-angle, compound eyes of the ant allow for a field of view that is significantly broader than that of vertebrates. This "panoramic vision" likely enables them to collect vital environmental cues from the sides and even slightly behind them, which they then process to guide their backward movement.
Data-Driven Implications for Robotics and AI
The study of Cataglyphis velox has implications that extend far beyond the field of entomology. Robotics engineers, particularly those working on autonomous navigation for small-scale drones and ground robots, have long looked to insects for inspiration.
The "path integration" model used by ants is highly computationally efficient. Unlike GPS-based systems that require satellite communication and massive data processing, the ant’s system relies on local sensing and memory. If engineers can replicate the way these ants use "visual snapshots" and path integration to navigate backward, it could lead to the development of more resilient autonomous systems capable of operating in GPS-denied environments.
Future Directions in Navigation Research
Despite the recent breakthroughs, significant questions remain. Scientists are currently planning follow-up experiments to isolate which specific visual features—such as edge contrast, brightness, or specific landmark shapes—are the most influential in the ant’s decision-making process.
By manipulating the visual environment in even more precise ways, such as using high-resolution LED screens to simulate varying landscape features, researchers hope to map the hierarchy of the ant’s navigational priorities. Does the ant prioritize the sun’s angle over the visual landmarks, or is the reliance dynamic?
Furthermore, the role of social interaction in navigation remains an area of interest. While Cataglyphis velox are generally solitary foragers, they exist within a larger colony structure. Whether they share information about path adjustments through chemical signaling or physical contact during the foraging process remains a subject of ongoing investigation.
Conclusion
The Spanish desert ant, Cataglyphis velox, serves as a remarkable model for the study of spatial cognition. Their ability to successfully navigate the hostile terrain of the desert while burdened by food and moving in reverse is not merely a survival tactic; it is a sophisticated display of sensory integration. By balancing internal biological clocks, celestial navigation, and visual memory, these ants demonstrate that intelligence in the natural world is not defined by size, but by the efficiency and adaptability of the organism’s interaction with its environment. As researchers continue to peel back the layers of this behavior, the lessons learned from these tiny foragers will undoubtedly inform our understanding of navigation, both biological and mechanical, for years to come.